 Sithija Ranaraja
All projectsPerception, AI
LiDAR perception
Detecting and tracking people directly from laser scans
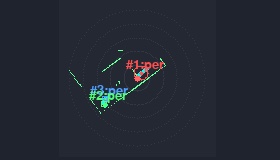
Cameras have trouble with lighting and raise privacy questions, so this perception layer works on the laser scan alone. I did the data collection and labelling, the model training, the multi-frame tracker and the deployment, and tuned it on site until it ran reliably.
- Type
- Hardware
- Period
- 2026
- Role
- End-to-end AI system development
- Stack
- Python, PyTorch, U-Net segmentation, 2D LiDAR, ROS 2, multi-object tracking
Challenge
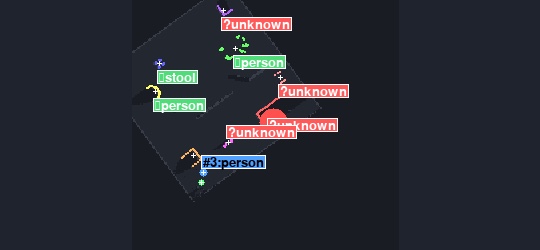
A 2D scan is sparse. In a single frame a person, a chair leg and a wall corner can look the same.
Approach
A U-Net segments the scan into classes. A zero-shot path lets it take on new object types without retraining from scratch. A tracker follows people and moving objects across frames and keeps their identities. I validated the tracker in simulation against moving and static targets before the hardware.
Result
Deployed and running on the target hardware.
What I built
- Data collection, labelling, training, tracking and deployment
- U-Net semantic segmentation on LiDAR data
- Zero-shot recognition of new objects
- Real-time human and dynamic-object tracking
From the project